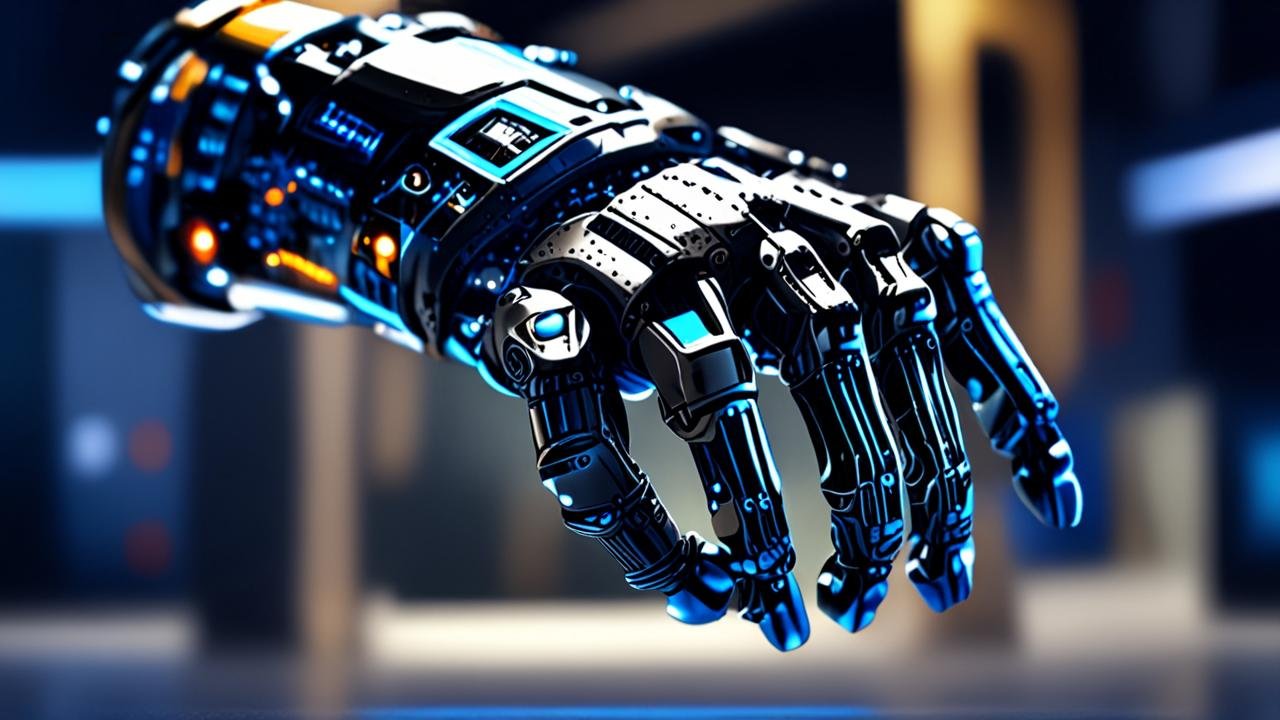
Boston Dynamics Just Dropped New Robot Hands for Atlas and Yes, They're Creepy
Boston Dynamics is back at it, trying to make their Atlas robot more human-like by swapping its claws for fancy new four-fingered grippers. It is an impressive engineering flex, but one has to wonder if we are just speeding up our own replacement.
The team at Boston Dynamics has unveiled a new hand design for their Atlas humanoid, ditching the old seven-degree-of-freedom grippers for a four-fingered, thirteen-degree-of-freedom powerhouse. These hands are built specifically to handle the clumsy reality of industrial tools—think drills, grinders, and welding torches—without needing fragile cables running through the joints.
By utilizing direct-drive actuators and a design that mimics human kinematics, the engineers have created something that can perform precise pinches or heavy-duty grips. They ditched the pinky finger because, frankly, the math says it adds zero value, proving that even robots suffer from a bit of minimalist elitism.
The training process relies heavily on sim-to-real transfer, where the robot learns how to manipulate objects in a virtual sandbox before ever touching a physical bolt. The system is designed to handle high-frequency feedback, meaning these mechanical hands can feel their way through tasks with surprising delicacy, all while maintaining the industrial strength needed for factory work.
It is only a matter of time before these metallic appendages are doing everything better than the average intern, leaving us to wonder if the future of work is just a really expensive Boston Dynamics subscription service. The convenience of having a robot that never complains about overtime or union dues is clearly outweighing the existential dread of being outperformed by a four-fingered hunk of metal.
Source: Boston Dynamics
Comments
Help shape the next version: Add context or suggest a correction. AI review can add points toward a rewrite. Reviews and updates may take time; a full meter does not guarantee a new version.